Manipulators for Low Ceilings: LIBRA MANIFLEX, the mobile solution for compact industrial spaces
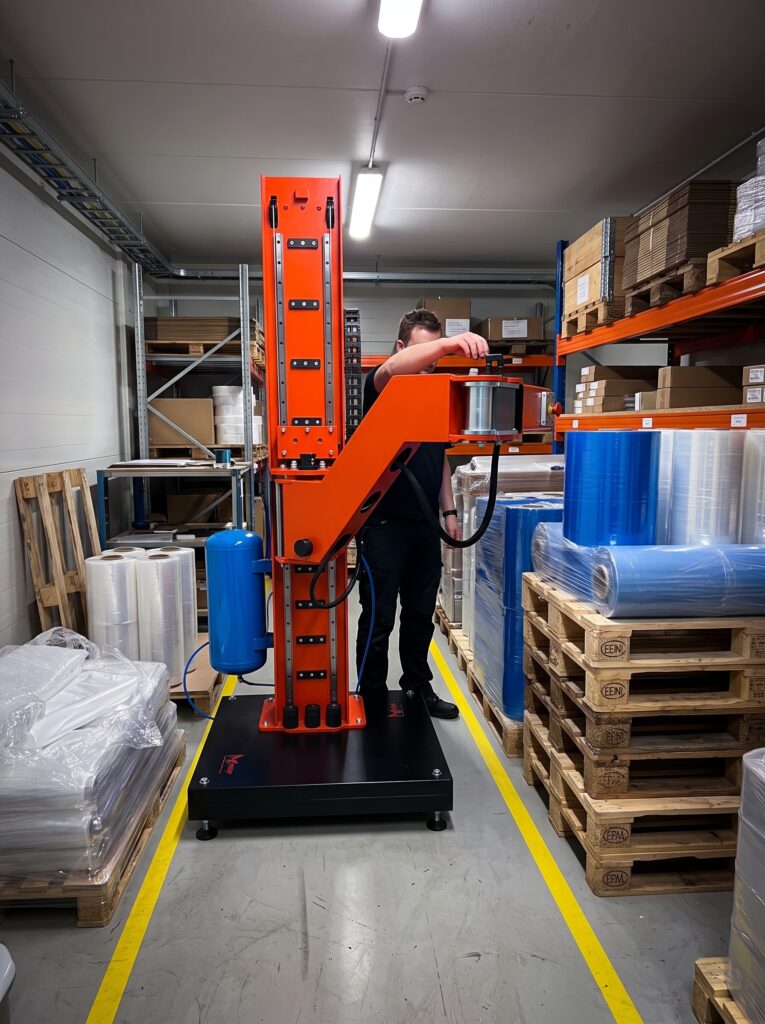
How can industrial loads be handled when the available height is limited?
In production areas with low ceilings, narrow access points, or closely spaced machinery, installing a traditional industrial manipulator can be particularly challenging.
LIBRA by MANIFLEX, a brand of Move Italy, is a mobile vertical-column manipulator with an articulated arm, designed to meet the needs of lifting, handling, and positioning loads even in environments with significant space constraints.
Its distinctive feature is the ability to adapt the manipulator’s geometry to the company’s operating conditions, rather than requiring significant changes to the production layout.
Industrial manipulators for low ceilings: What are the challenges?
Many industrial handling systems require a considerable installation height, especially when they use overhead structures, traditional lifting arms, or elevated handling systems.
However, not all production environments meet these conditions.
The most common restrictions pertain to:
Low ceilings and limited headroom.
Industrial doors and entrances with limited headroom.
It is not possible to install jib cranes or suspended structures.
Limited maneuvering space between machinery and production lines.
The need to move loads to different locations.
Controlled environments and cleanrooms with specific dimensional constraints.
In these situations, choosing a compact mobile manipulator can be an alternative to traditional fixed installations.
LIBRA MANIFLEX: a mobile manipulator designed to operate in confined spaces
LIBRA stands out for its compact vertical design, combined with an articulated arm that allows it to reach different points within the work area without necessarily requiring suspended support structures.
The machine can be configured based on the available height, the type of load, and the required movements.
A concrete example is a LIBRA configuration designed to operate inside a cleanroom with a maximum available height of just 2 meters.
Despite this constraint, the proposed solution includes:
The height of the structure is adapted to the work environment.
Compact base measuring 850 × 850 mm.
Articulated arm with a working radius of up to 2 meters.
Handling capacity of up to 120 kg within a 2-meter radius in the configuration described.
Fully pneumatic handling system.
Gripper customized for the specific component
These features demonstrate that it is possible to design an industrial manipulator even for environments where traditional solutions are limited by space constraints.
The performance specifications and dimensions listed refer to a specific application that has been implemented and may vary depending on the required configuration.
Mobile structure: flexibility without permanent installations
One of LIBRA’s main advantages is its mobile and repositionable design.
Unlike column-type manipulators that are permanently anchored to the floor, LIBRA can be designed with a self-supporting base that allows the system to be moved between different operating areas, as specified by the configuration.
This solution is particularly appealing to companies that need to:
Moving components between multiple workstations.
Frequently change the production layout.
Avoid permanent installations.
Operating in environments where it is not possible to make changes to existing structures.
The system’s mobility also makes it possible to consider a more flexible use of material-handling equipment within the department.
Articulated arm and vertical lift for precise positioning
A manipulator designed for low ceilings must not only be compact in size but also capable of efficiently moving the load within the available space.
That is why LIBRA combines vertical lifting with an articulated arm, making it possible to reach different points in the workstation and guide the component during handling operations.
Gripping equipment can be designed to perform specific operations, including:
Picking up and lifting the load.
Lateral displacement.
Installation on machinery or production lines.
Rotation and tilt of the component.
Transition from the vertical position to the horizontal position and vice versa.
The ability to customize these movements makes LIBRA suitable even for applications in which it is not enough to simply lift a weight, but it must also be positioned with precision.
Custom Gripping Systems: One Manipulator, Many Applications
Another distinctive feature of LIBRA is the ability to develop gripping attachments specifically tailored to the product being handled.
The manipulator can be equipped with pneumatic grippers, mechanical systems, expanders, suction cups, magnets, or custom-designed gripping devices.
In the configuration developed for a space with limited headroom, LIBRA has been equipped with a gripping system designed to handle reels with different inner diameters, which also allows the load’s orientation to be changed.
This flexibility makes the manipulator particularly well-suited for loading and unloading machinery, feeding production lines, and assembling and handling industrial components.
Mobile Pneumatic Manipulator for Cleanrooms and Controlled Environments
In controlled manufacturing environments, space constraints are often accompanied by additional requirements regarding materials, contamination, cleanliness, and equipment integration.
LIBRA can be designed in a fully pneumatic configuration, with components and design features tailored to the required operating conditions.
This feature makes it particularly attractive for applications in the following sectors:
Pharmaceutical and biomedical.
Electronics and semiconductors.
Food.
Chemist.
Manufacturing and assembly in controlled environments.
Compliance with the specific cleanroom classification and facility protocols must be verified during the design phase.
MANIFLEX LIBRA: When space is limited, the solution is a custom design
It is not always possible to modify a production facility to install a traditional lifting system.
In many cases, however, it is necessary to develop a material-handling solution that can adapt to the existing environment, while taking into account its dimensional and operational constraints.
This is precisely the principle behind LIBRA MANIFLEX.
A mobile, compact, and customizable industrial manipulator designed to handle loads even where available height and maneuvering space pose a challenge.
Are you looking for a manipulator for low ceilings or confined industrial spaces?
The technical team at Move Italy can evaluate your application and design a LIBRA configuration based on the available height, the load weight, the operating radius, and the required handling operations.


